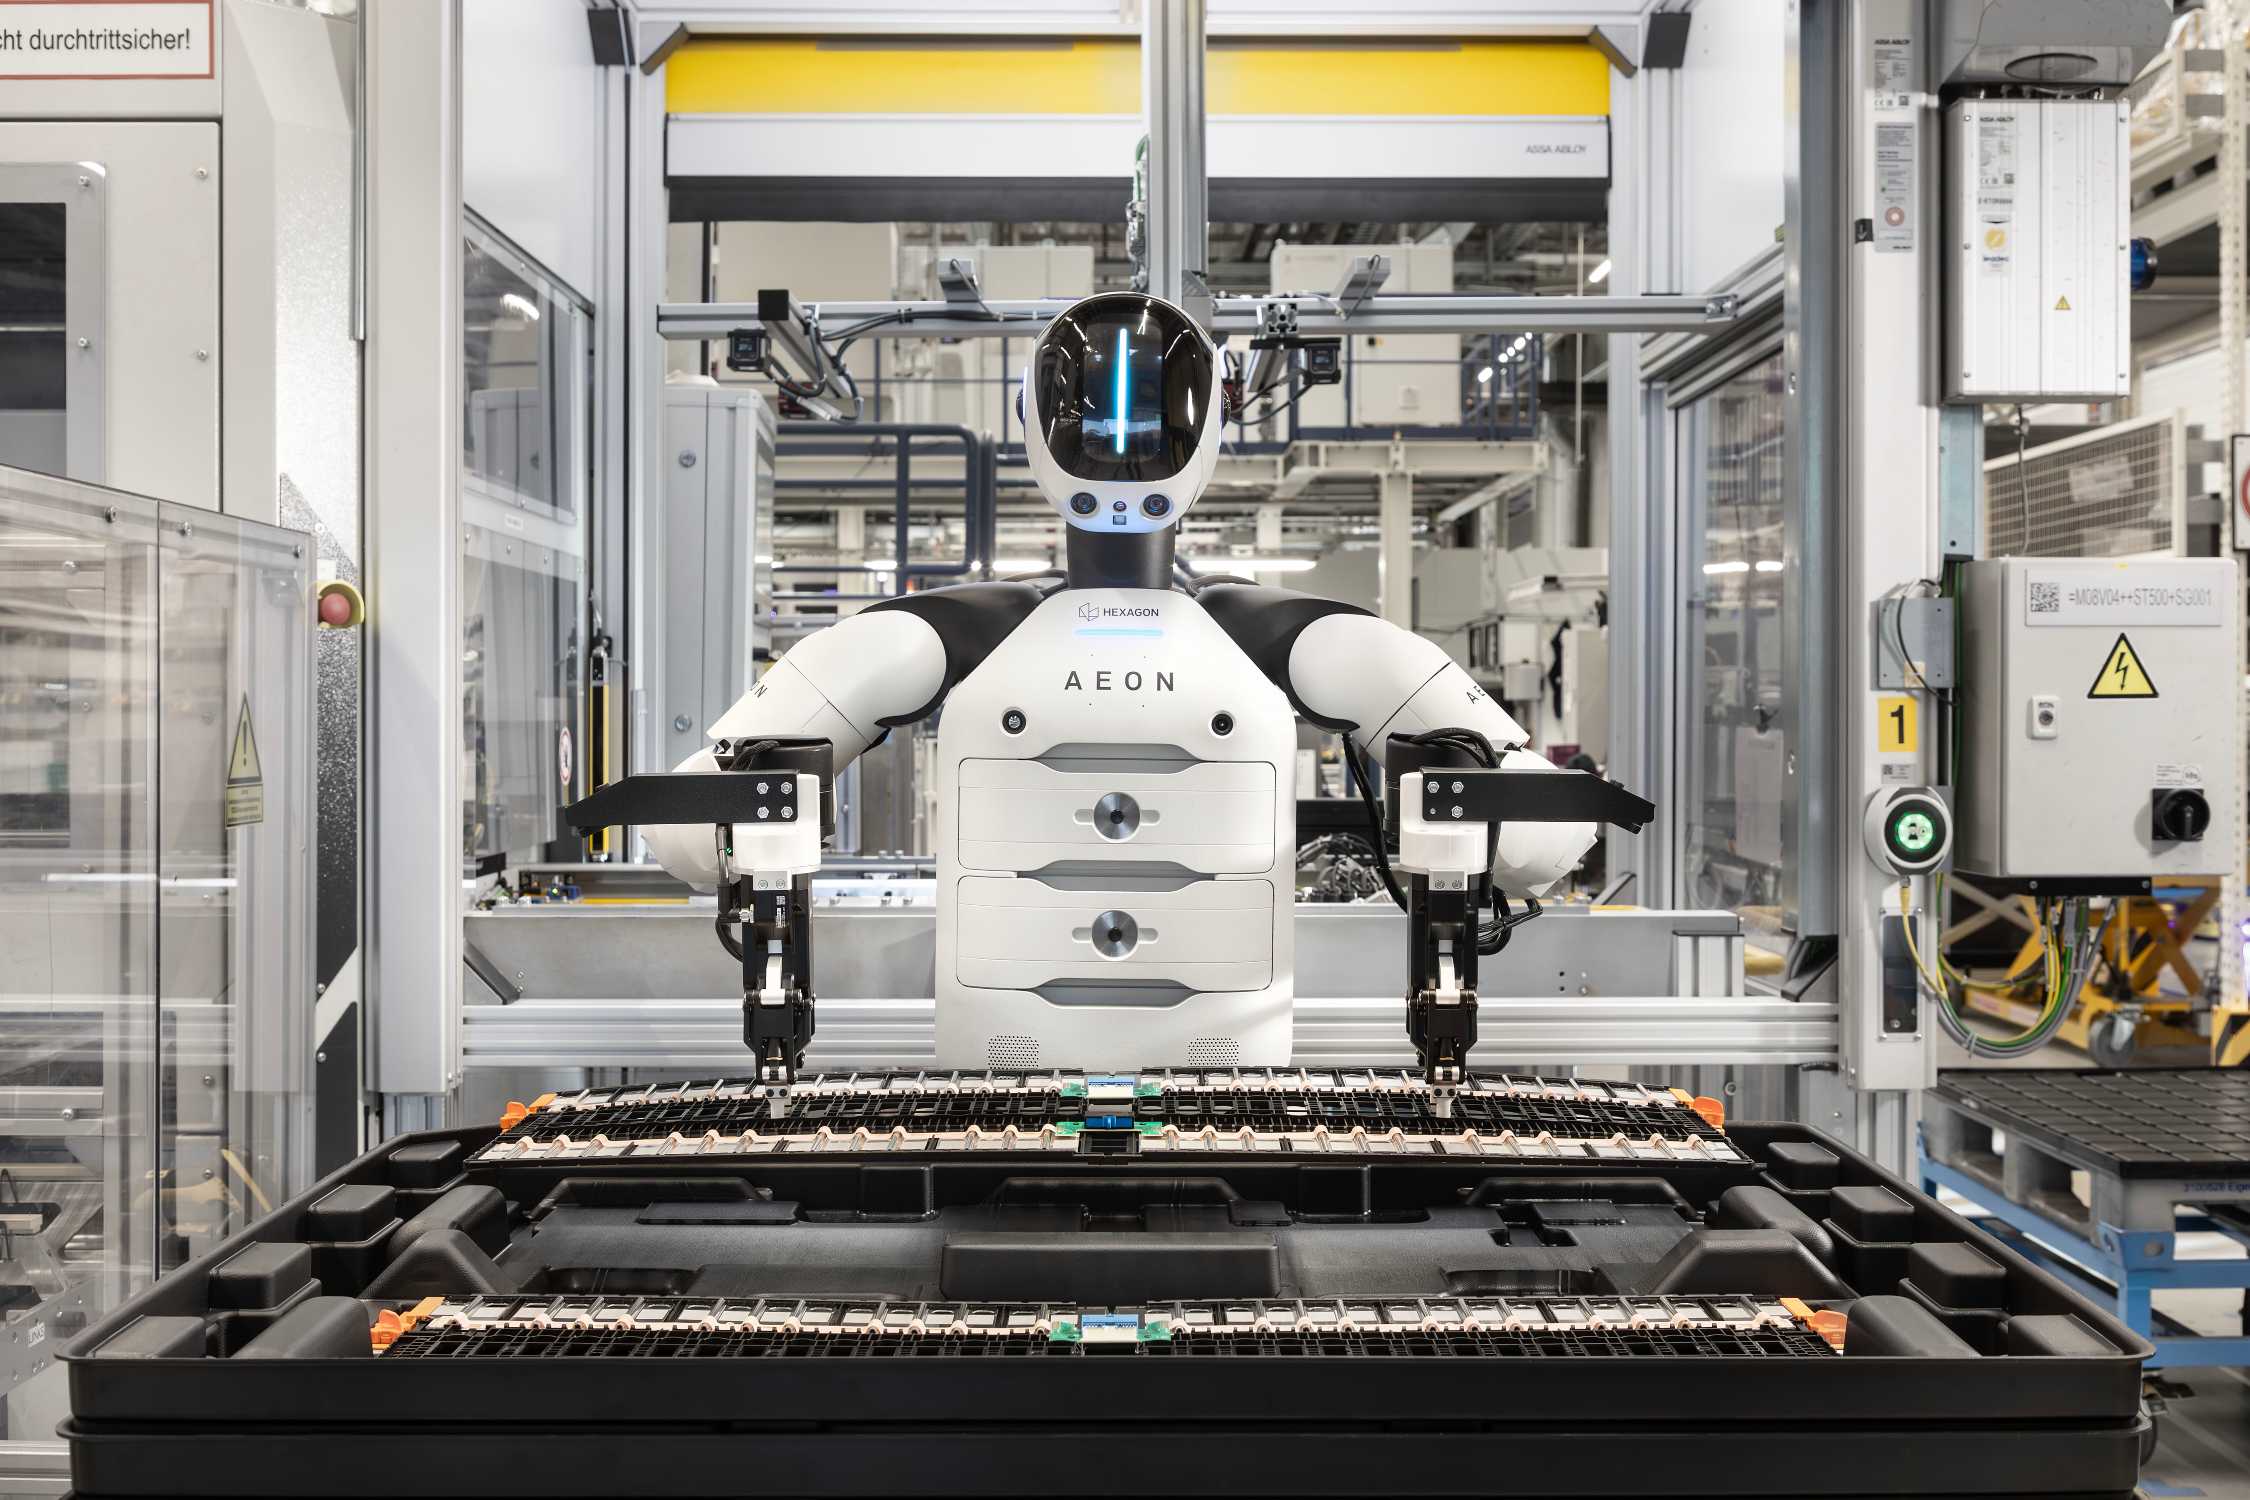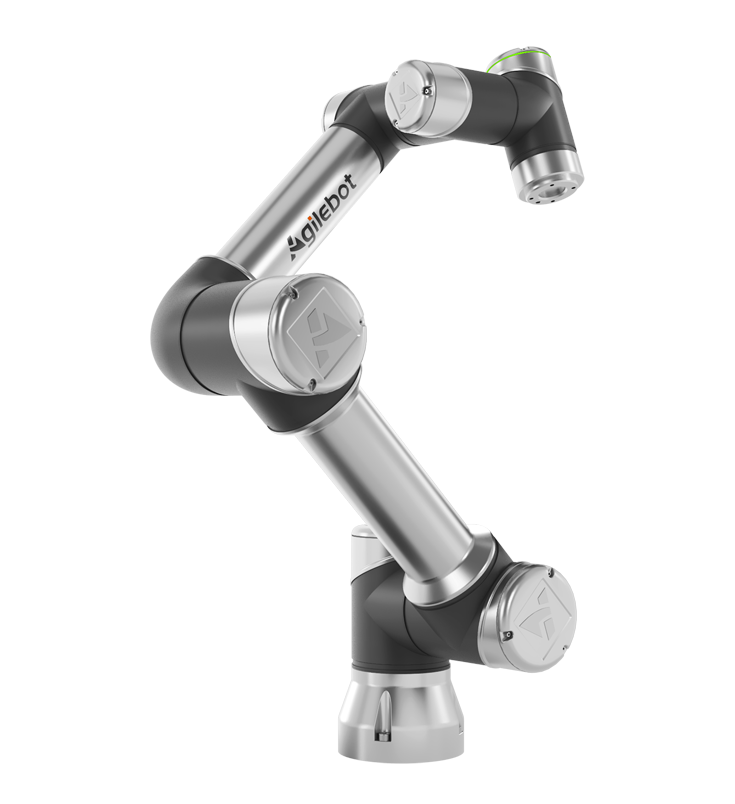
Agilebot provides official ROS2 support for C5A, C7A, C12A and C16A cobots, including robot models and integration examples. Driver availability helps engineering evaluation but does not establish a commissioned production application.
Start with one inspection or machining station. Present parts in a tray, load the fixture and retrieve the part after the machine signals completion. Staff retain responsibility for replenishment and exceptions.
Size the payload for the combined part and gripper. Check reach, orientation, door signals, part detection and recovery after a machine fault. Collaborative hardware does not make every application safe around people: tooling and workpieces remain part of the assessment.
Original sources
- Agilebot — official ROS2 project ↗ Publication date not stated
Source summaries and application analysis by COCON. Pilot ideas are proposals, not claims of completed COCON projects or confirmed product availability.
Could this work in your operation?
Share your workflow, location and target outcome. Start with a feasibility assessment, then validate the technology and define a pilot.
Discuss your project ↗ Email our team ↗