Robot Phoenix / 6-Axis
Mantis830-A6
Mantisシリーズの多関節ロボット。6軸の動作により、工程に応じたツールの位置・姿勢を制御します。
Payload6kg
Working radius830mm
Axes6
Repeatability0.02mm
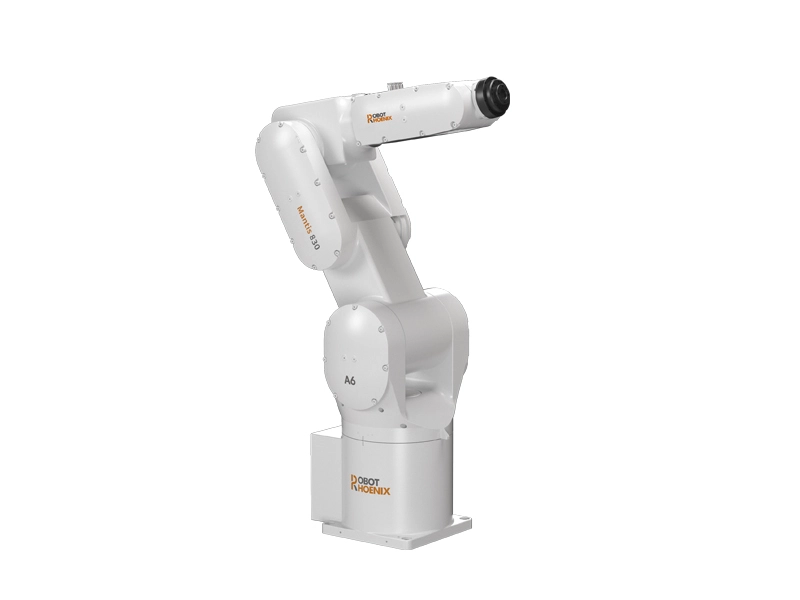
Product image: Robot Phoenix · Mantis830-A6
Technical specifications.
初期検討用のメーカー公開情報です。ご注文前に構成、供給状況、最終仕様をCOCONへご確認ください。
| Robot Model | Mantis830-A6 | ||
|---|---|---|---|
| Load | 6kg | ||
| Working Radius | 830mm | ||
| Number of Axles | 6 | ||
| Motion | Axial Motion | Scope of Work | Maximum Speed |
| A1 Joint: Rotation of the First Mechanical Arm | -175°-+175° | 288°/s | |
| A2 Joint: Swing of the Second Mechanical Arm -123°-+97° | -90°-+126° | 240°/s | |
| A3 Joint: Swing of the Third Mechanical Arm -66°-+201° | -201°-+66° | 415°/s | |
| A4 Joint: Rotation of the Fourth Mechanical Arm | -180°-+180° | 421°/s | |
| A5 Joint: Swing of the Wrist Component -118°-+118° | -120°-+120° | 487.5°/s | |
| A6 Joint: Clamp End Rotation | -360°-+360° | 765°/s | |
| Integrated Signal Source | 12 Signals Are Set at the Wrist | ||
| Integrated Air Supply | 4-way Air (5bar) is Set at Wrist | ||
| Repetitive Positioning Accuracy | 0.02mm | ||
| Robot Installation | Table/Ceiling mounting | ||
| Degree of Protection | IP54 | ||
| Dimensions of Robot Base | 250mm×250mm | ||
| Robot Height | 1343.5mm | ||
| Weight | 59kg | ||
出典:Mantis830-A6 6-Axis Robot — Robot Phoenix ↗。2026年9月7日参照。「—」は原表の空欄を示します。最大値は実際のサイクルタイムや処理能力を保証するものではありません。
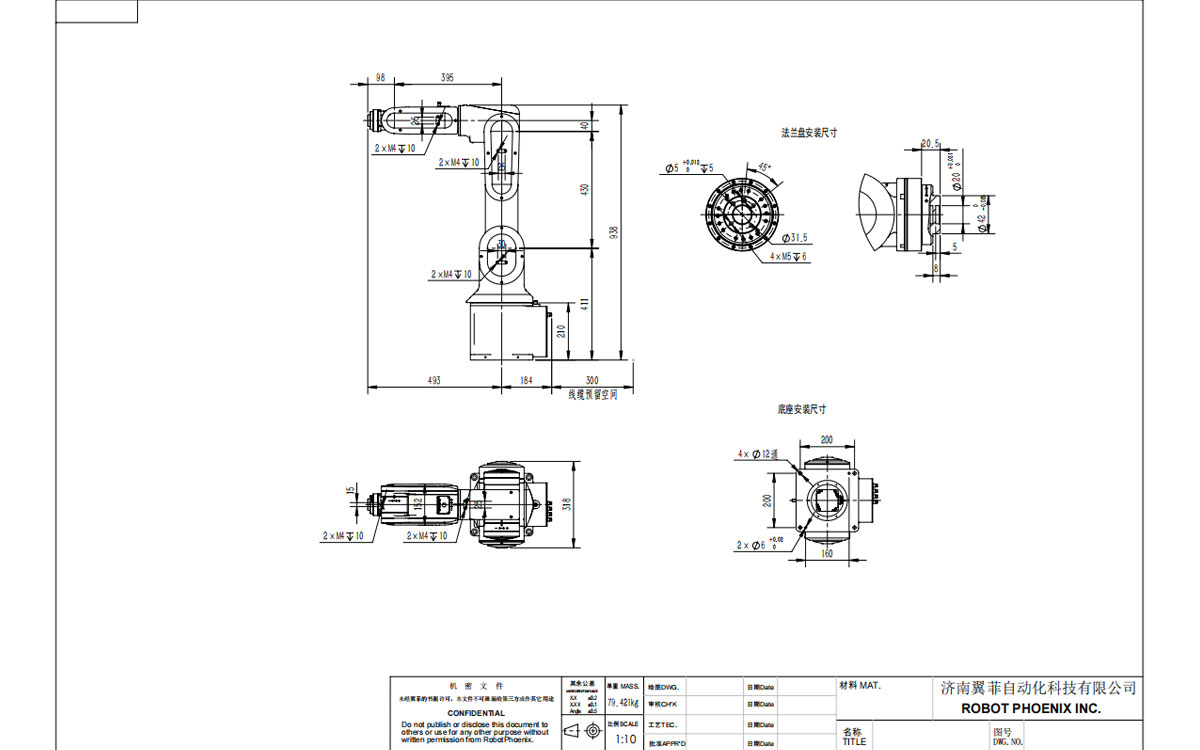
Images & technical drawings.
画像を拡大して寸法・詳細をご確認いただけます。製品画像・図表:Robot Phoenix。