Robot Phoenix / Wafer handling
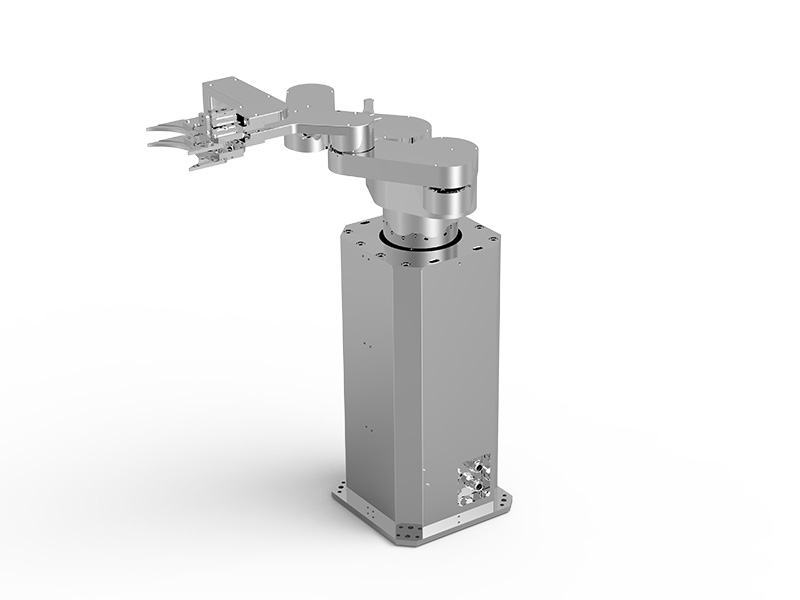
Lobster185Z340D-T2X0-C
Lobsterシリーズのウェハ搬送ロボット。アーム構成、動作範囲、清浄度、インターフェースを比較できます。
Rated payload2KG
ConfigurationTwo-armed
Degrees of freedom4
CleanlinessClass 100
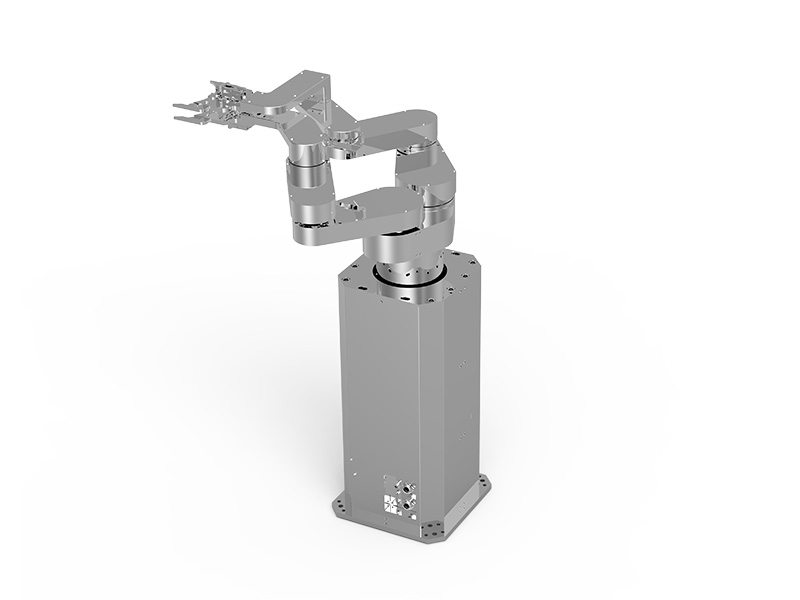
Product image: Robot Phoenix · Lobster185Z340D-T2X0-C
Technical specifications.
初期検討用のメーカー公開情報です。ご注文前に構成、供給状況、最終仕様をCOCONへご確認ください。
| Model | Lobster185Z340D-T2X0-C | |
|---|---|---|
| Type | Two-armed | |
| Applied Specification | ~300 | |
| Rated Payload | 2KG | |
| Degree of Freedom | 4 | |
| Range of Motion | Lifting Axis (Z) | 340mm |
| Rotating Axis (T) | 340deg | |
| Stretching Axis (R) | 360mm | |
| Maximum Speed | Lifting Axis (Z) | 400mm/s |
| Rotating Axis (T) | 260deg/sec | |
| Stretching Axis (R) | 1500mm/s | |
| Features | 1) Cleanroom environment. 2) Robotic Arm Length: 135mm; 185mm. 3) Two-armed structure shortens the operation time of wafer replacement. 4) Mapping Sensor to detect if wafers are there, if overlying or tilting. 5) Specifications can be customized according to requirements. | |
| Re-positioning Accuracy | ±0.1mm | |
| Leak Rate | — | |
| Cleanliness | Class 100 | |
| Interface | I/O interface | 4 configurable digital inputs; 4 configurable digital outputs; 8 general digital inputs; 8 general digital outputs; (Re-extensible 8 digital inputs/outputs). |
| Ethernet | 1 | |
| USB | 2 | |
| RS232/RS485 | 1 | |
| Communication Protocol | Modbus-RTU/TCP、Socket | |
| Arm Length (R) | 185mm | |
| Vertical Stroke (Z) | 340mm | |
| Machine Table Height (H) | 605mm | |
| Actuator Length (L) | Demand-based | |
| Height from Table to Stroke’s Down Position (H) | 250mm | |
出典:Lobster185Z340D-T2X0-C Wafer Robot — Robot Phoenix ↗。2026年9月7日参照。「—」は原表の空欄を示します。最大値は実際のサイクルタイムや処理能力を保証するものではありません。
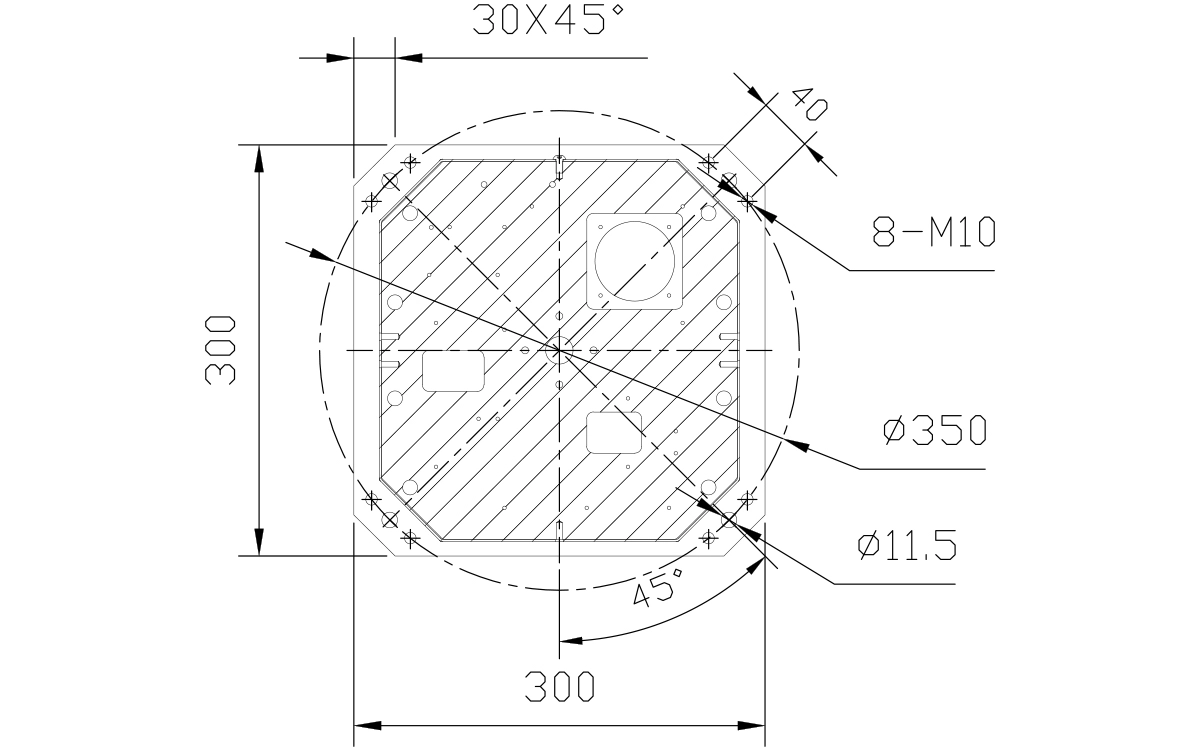
Images & technical drawings.
画像を拡大して寸法・詳細をご確認いただけます。製品画像・図表:Robot Phoenix。