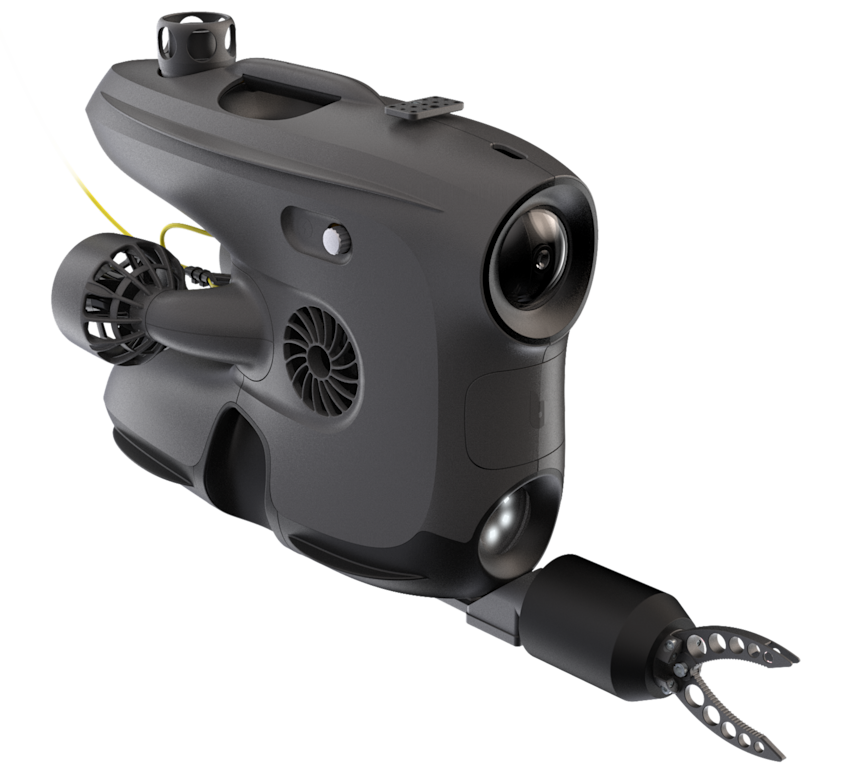
Blueye X3 is an underwater ROV for professional inspection, with a camera and optional peripherals such as sonar and measuring tools. An underwater drone is not necessarily autonomous: an operator controls the vehicle and interprets its surroundings.
A limited pilot could document one jetty pile or part of a vessel when operating conditions permit. Follow an inspection plan and store footage with location and findings. The inspector decides whether further examination is needed.
Assess turbidity, currents, launch access, tether snagging and vessel traffic. Sonar may help where visibility is poor. Visual footage does not automatically replace inspections required by the asset owner or classification body. Begin with one structure and one inspection objective.
Original sources
- Blueye Robotics — X3 ↗ Publication date not stated
Source summaries and application analysis by COCON. Pilot ideas are proposals, not claims of completed COCON projects or confirmed product availability.
Could this work in your operation?
Share your workflow, location and target outcome. Start with a feasibility assessment, then validate the technology and define a pilot.
Discuss your project ↗ Email our team ↗